People / Emilia Silvas
Principal investigator
Emilia Silvas
Assistant professor | Smart & safe mobility – the safety envelope
- Institution
- Eindhoven University of Technology
- Work package
- In NEON
- 2020 onwards
- Now
- Associate Professor (part-time), Control Systems Technology section, Department of Mechanical Engineering, Eindhoven University of Technology.
Leader of WP6b (Automated vehicle safety / the safety envelope); supervisor and co-author of Caspar Hanselaar.
Expertise: Control systems technology, cooperative and autonomous vehicles
Emilia Silvas works at Eindhoven University of Technology on cooperative and automated vehicle systems and mobile robots, with interests in advanced control, optimal system design and data-driven methods. She received her PhD from TU/e in 2015 on integrated optimal design of hybrid electric vehicles.
About me
I love to discover how I can contribute to a better society and a better live for the next generations by smart and sustainable solutions. I believe that if each of us contributes actively, society will become improve. I also support the idea that developed countries have a categorical imperative to help developing countries, such that all people have access to a better life. I combine research and practice by working at TNO and TU/e. I live in Eindhoven with my husband and I’ll be driving a plug-in car to support our sustainability goals. I enjoy diving into complex problems, derive good questions, and start with a white sheet of paper. I believe that education is the primary pillar for a good society. In an era of Lifelong Learning and complex automated reasoning understanding education is the ultimate key to success. That’s why I added for you a picture from the start of my NL educational journey, a place which I liked very much when I moved here.
Personal Motivation
I’m coming from a family of engineers and because I’m very passionate about robotics, automated driving is like a playground for me. My background in between Computer Science and Mechanical Engineering helps me a lot to bridge the two worlds together.
Smart & safe mobility - the safety envelope
I hope on the long run my work will have a positive effect in society. That’s why I love my work now, as it’s directly connected to developing safer roads. Globally, 2-3 people die each minute in road accidents. This is the leading cause of death for children and young adults. More than half of all deaths are among vulnerable road users. I think through well-designed technologies (e.g. connected and/or automated vehicles), these numbers can go down.
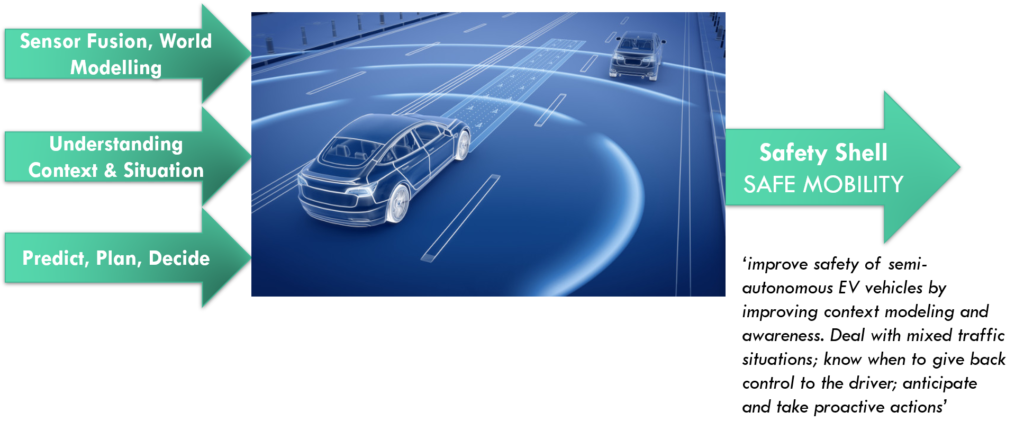
As shown in next slide, if we can develop enhanced methods for sensor fusion, world-, situation- and context-modeling, planning and decisions we will enable better and safer actions of the automated vehicle.
Link to other neon research
I’m glad I will be in the same WP with Gijs Dubbelman, from TU/e Electrical Eng., to discuss reaching a holistic scene understanding, able to detect and interpret (inter-) object behavioral, model the scene and the context around the car.
I also look forward to listen and develop the work with the WP partners, SWOV (Peter van der Knaap), NXP (Gerardo Daalderop and Maurice Geraets), and RDW.
On a broader scale, I want to connect to other partners to discuss network level implications (e.g. MaaS and Hubs (Tom van Woensel), traffic level, logistics systems, V2X), connections with the powertrain design, e.g. Theo Hofman, Steven Wilkins, Mauro Salazar), the human factor (Reint Jan Renes) and other topics in the mobility cluster. I am looking for sharing data, methods, creating links and co-develop.
Profile text from the former NEON website.
✎ draftPhD researchers supervised

Publications and talks
- Identification of Hazardous Driving Scenarios Using Cross-Channel Safety Performance Indicators (conference-paper, 2025)
- Maintaining Stability During Channel Switching in Multi-Channel Automated Driving Systems (conference-paper, 2025)
- The Safety Shell: An Architecture to Handle Functional Insufficiencies in Automated Driving (journal-article, 2024)
- Evaluation of the Safety Shell Architecture for Automated Driving in a Realistic Simulator (conference-paper, 2024)
- Characterization and Mitigation of Insufficiencies In Automated Driving Systems (conference-paper, 2023)
- Detection and Mitigation of Performance Limitations and Faults in Autonomous Vehicles The Safety Shell (conference-paper, 2022)